Master Thesis
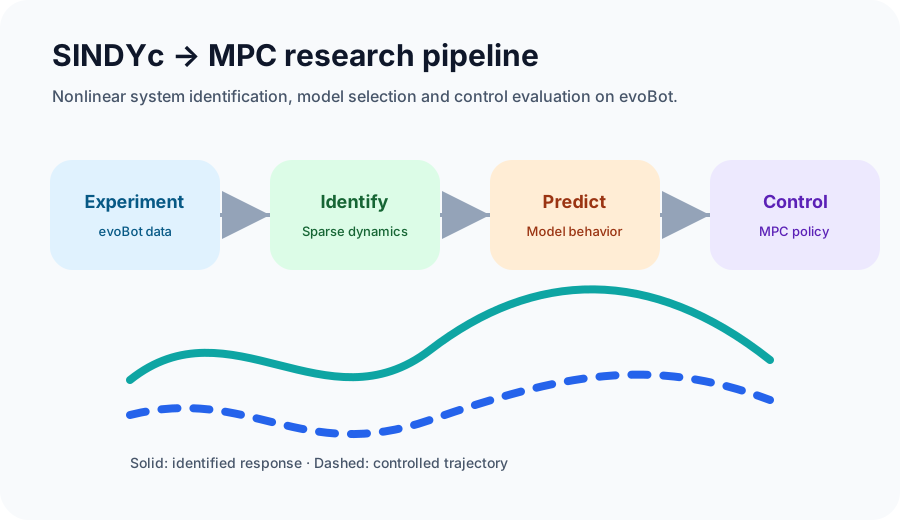
Master Thesis: SINDYc + MPC
Nonlinear system identification and control using Sparse Identification of Nonlinear Dynamics for MPC on evoBot.
Open project →Projects & case studies
These pages explain what I worked on, why it mattered, the tools and standards involved, and what a recruiter should notice. Confidential company details are intentionally kept public-safe.
Nonlinear system identification and control using Sparse Identification of Nonlinear Dynamics for MPC on evoBot.
Open project →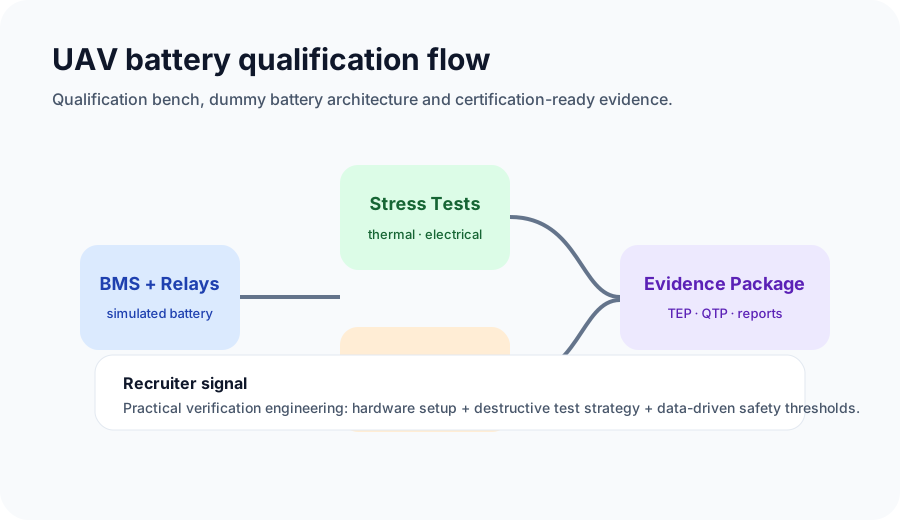
Qualification, acceptance testing, dummy battery architecture, SoC mapping and safety-threshold validation.
Open project →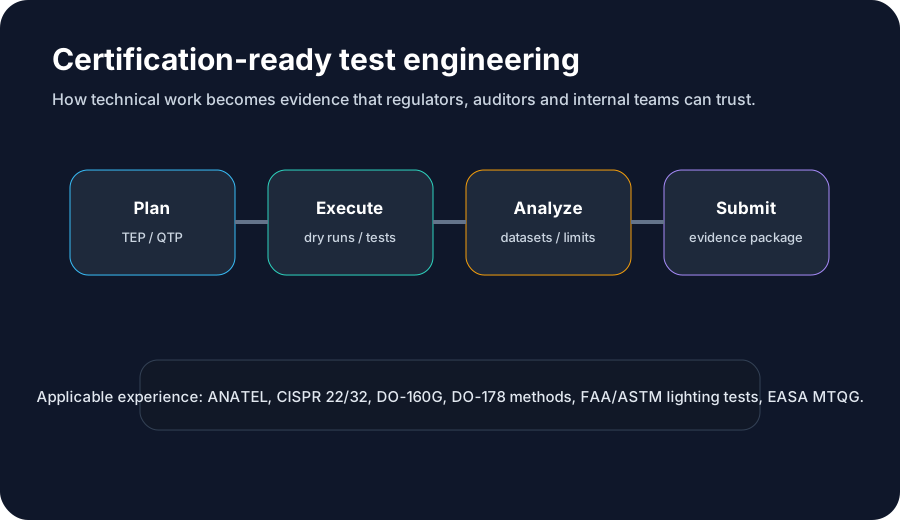
TEP/QTP/ATP, ANATEL documentation, EMI/EMC testing, DO-160G lighting tests and homologation evidence.
Open project →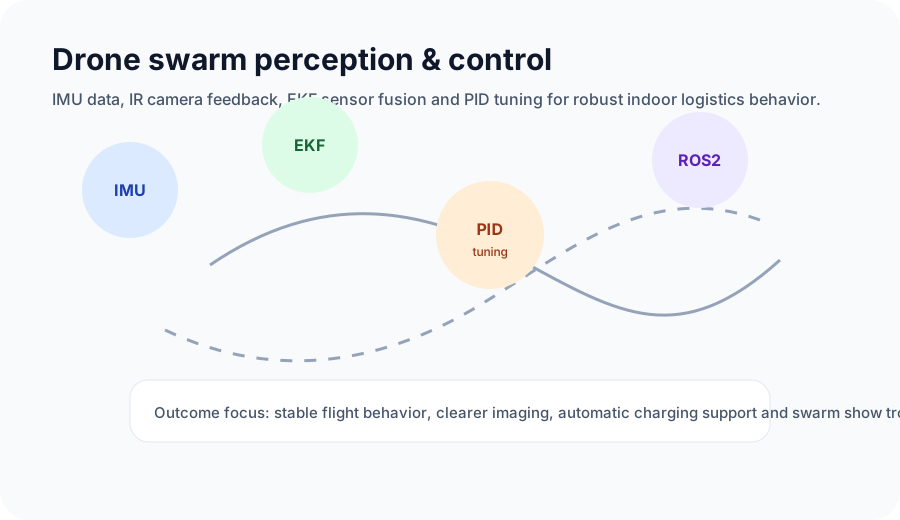
6DoF IMU datasets, EKF sensor fusion, PID tuning, ROS/ROS2 migration and indoor logistics demos.
Open project →
IEC 61850, IEC 61970-301, CIMPY 3.0, IID/SCD generation and Python automation framework.
Open project →
VTOL/MALE autopilot control laws, EKF altitude estimation, BLDC selection, wiring harness and BOM creation.
Open project →
EASA-compliant Master-QTG documentation for Airbus A320/A330 simulator maintenance and qualification.
Open project →
Model Predictive Control for upper-body balance during walking and ball-kicking in a soccer robot project.
Open project →The master thesis includes the public thesis link and code repository from my LinkedIn profile. Company work is presented as public-safe case studies; detailed internal reports are not published online unless cleared for sharing.